EurEx-LUNa
EurEx - Persistent under-ice navigation


One important aspect of future missions to ice-covered moons within our solar system is the exploration of the oceans underneath the ice. Based on the exploration concept developed in the Europa-Explorer project, the aim of the EurEx-LUNa project is to further evolve the under-ice navigation and exploration capabilities of an autonomous system and subsequently evaluate them in an analog mission. In order to allow for persistent exploration in challenging and difficult to access environments, both the software and the hardware of an autonomous underwater vehicle must be thoroughly tested and continuously improved. An essential part is the safe return of the underwater vehicle and to successfully attach to the docking interface, allowing data and energy exchange. To evaluate the capabilities and robustness of the overall system an analog mission will be carried out in an ice-covered lake.
| Duration: | 01.03.2020 till 30.09.2023 |
| Performing institution: | German Research Center for Artificial Intelligence GmbH |
| Website: | https://www.dfki.de/web/forschung/eurex-abisko |
| Application Field: |
Underwater Robotics
Space Robotics |
| Related Projects: |
EurEx
Europa-Explorer
(12.2012-
04.2016)
EurEx-SiLaNa
EurEx-Safe Long-Term Navigation
(09.2017-
10.2019)
CUSLAM
Localization and mapping in confined underwater environments
(09.2009-
07.2012)
|
| Related Robots: |
DeepLeng
Exploration-AUV for Long-Term Missions
Teredo IceShuttle
Through-Ice-Cap Transfer-Vehicle & Base Station
BlueROV2
Documentation vehicle
DAGON
Exploration AUV for long-distance-missions
|
Funding

- Funding note
- The EurEx-LUNa project is funded by the German Ministry for Economic Affairs and Climate Action (BMWi) (Grant No. 50 NA 2002).
Project details
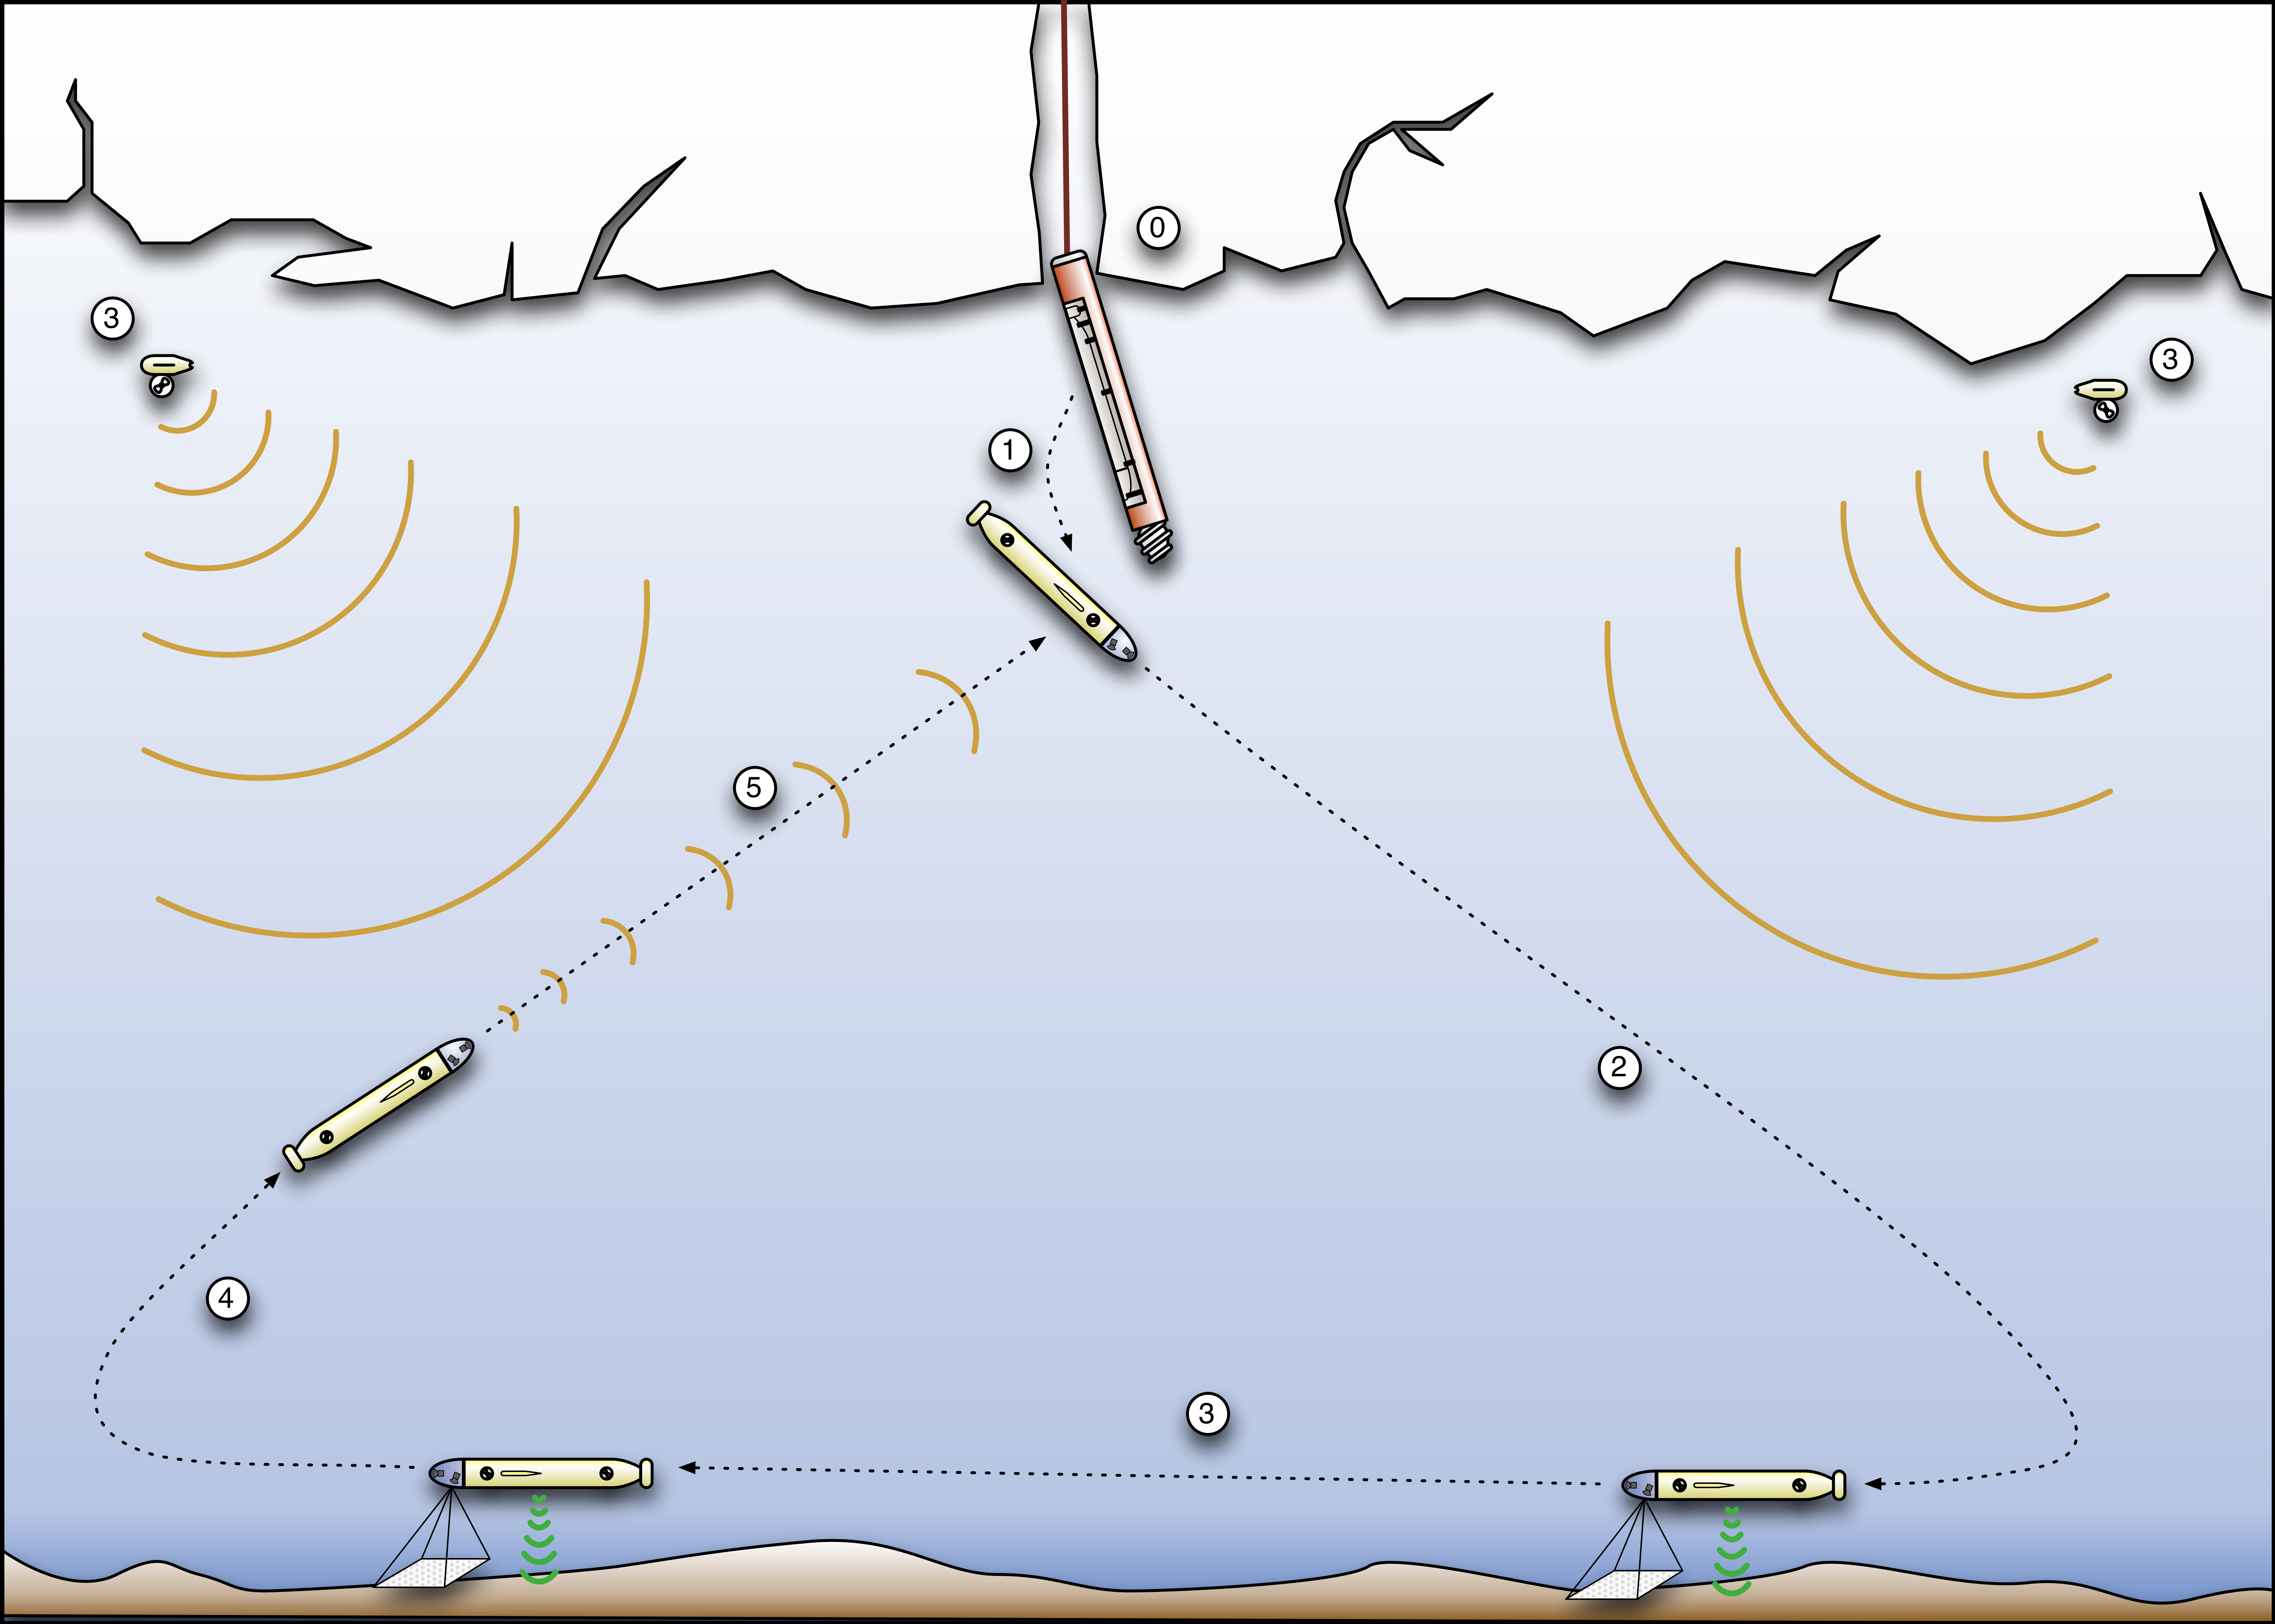 Foto: Jan Albiez, DFKI GmbH
 Foto: Annemarie Popp, DFKI GmbH
 Foto: Annemarie Popp, DFKI GmbH
 Foto: Annemarie Popp, DFKI GmbH
 Foto: Annemarie Popp, DFKI GmbH
Videos
EurEx-LUNa: Under Ice Navigation of AUV DeepLeng

In this short video we explain under ice navigation of the AUV Deep Leng.
EurEx-LUNa: Preparing a Mission to Jupiter's moon Europa. Under-Ice field test with the AUV DeepLeng

At the end of the third phase of the Europa Explorer project for long-range underwater navigation (EurEx-LUNa), DFKI researchers are now conducting the final field tests in the Abisko National Park in northern Sweden. There, they are testing the DeepLeng autonomous underwater vehicle in frozen Lake Torneträsk to prove the feasibility of the concept for autonomous under-ice navigation.
AUV DeepLeng: docking under Ice
AUV DeepLeng: starts a mission
Publications(9)
9 publications · BibTeX · approx. 5 KB
2024
-
Conference
A Deep-Learning Approach for Visual Detection of an AUV Docking StationIn: Proceedings of Oceans 2024, Halifax, CA · 2024
-
Conference
Design of a Compact, Agile AUV with Large Thrust-to-Weight RatioIn: 2024 IEEE OES AUV Symposium, Boston, US · 2024
2023
-
Conference
Towards Robust Autonomous Underwater Docking for Long-Term Under-Ice ExplorationIn: Proceedings of Oceans 2023, Limerick, IE · 2023
-
Conference
AUV Trajectory Optimization with hydrodynamic forces for icy moon explorationIn: Proceedings of the 17th Symposium on Advanced Space Technologies in Robotics and Automation, Leiden, NL · 2023
2022
-
Conference
Under-Ice Field tests with an AUV in Abisko/TorneträskIn: OCEANS 2022 - Hampton Roads, Virginia Beach, US · 2022
-
Conference
Spatial Acoustic Projection for 3D Imaging Sonar ReconstructionIn: 2022 International Conference on Robotics and Automation (ICRA) · 2022
2021
-
Conference
Deep Reinforcement Learning for Continuous Docking Control of Autonomous Underwater Vehicles: A Benchmarking StudyIn: Global OCEANS 2021, San Diego, US · Sep 2021
-
Conference
Online Model Adaptation of Autonomous Underwater Vehicles with LSTM NetworksIn: Online Model Adaptation of Autonomous Underwater Vehicles with LSTM Networks, Porto, PT, 1-6 · 2021
2020
-
Conference
From epi-to bathypelagic: Transformation of a compact auv system for long-term deploymentsIn: 2020 IEEE/OES Autonomous Underwater Vehicles Symposium (AUV), Memorial University of Newfoundland, St. John's, CA, 1-6 · 2020