SherpaUW
 Bild: Thomas Frank, DFKI
Technical Details
| Size: | The system has variable dimensions; smallest footprint: 1m x 1m, biggest footprint: 2.4m x 2.4m. Height ranges from 0.8m to 1.8m |
| Weight: | Approx 200kg |
| Power supply: |
LiPo primary battery: 44,4 V; 10 Ah LiPosecondary battery: 44,4 V; 10 Ah (autonomous hot switching) Alternatively: External AC/DC Power Supply
|
| Speed: | 0.7 m/s (max), 0.1 m/s (nominal) |
| Actuation/ Engine: |
4-wheel drive with active ground adaption,
alternatively short traverses of walking motion
|
| Sensors: |
- Force-Torque sensor FT-DELTA 160 at each wheel
- Inertial Measurement Unit KVH 1750
- USBL Evologics S2CR 48/78
- Camera Basler ACE
- LED lamps Bowtech
- Obstacle Avoidance Sonar Tritech Micron DST
- DVL Rowe SeaPilot
- Distributed Magnetometer Array
- Laser line projector
|
| Communication: |
Gigabit Ethernet (with umbilical), up to 31.2 kbit/s (acoustic without umbilical)
|
| On-Board Computer: |
IntelCore i7-4785T, 2,2GHz
|
| Structure and Mechanisms: |
- 6 DoF Manipulator
- 4x 5DoF Suspension Units
|
Organisational Details |
|
| Application Field: | Underwater Robotics |
| Related Projects: |
MARIOW
Maritime AI-Guided & Remote Operated Welding
(10.2022- 09.2025)
UWS
Evaluation of a novel technology for underwater robotic welding in the ports of Bremen.
(04.2026- 03.2027)
REMARO
Reliable AI for Marine Robotics
(12.2020- 11.2024)
TransTerrA
Semi-autonomous cooperative exploration of planetary surfaces including the installation of a logistic chain as well as consideration of the terrestrial applicability of individual aspects
(05.2013- 12.2017)
|
| Related Robots: |
SherpaTT
Expandable Rover for Planetary Applications
Leng
Exploration AUV for long-distance-missions
DAGON
|
Funding

- Funding note
- Funded by the German Space Agency (DLR Agentur) with federal funds of the Federal Ministry of Economics and Technology in accordance with the parliamentary resolution of the German Parliament. Grant no. 50 RA 1301.
System description
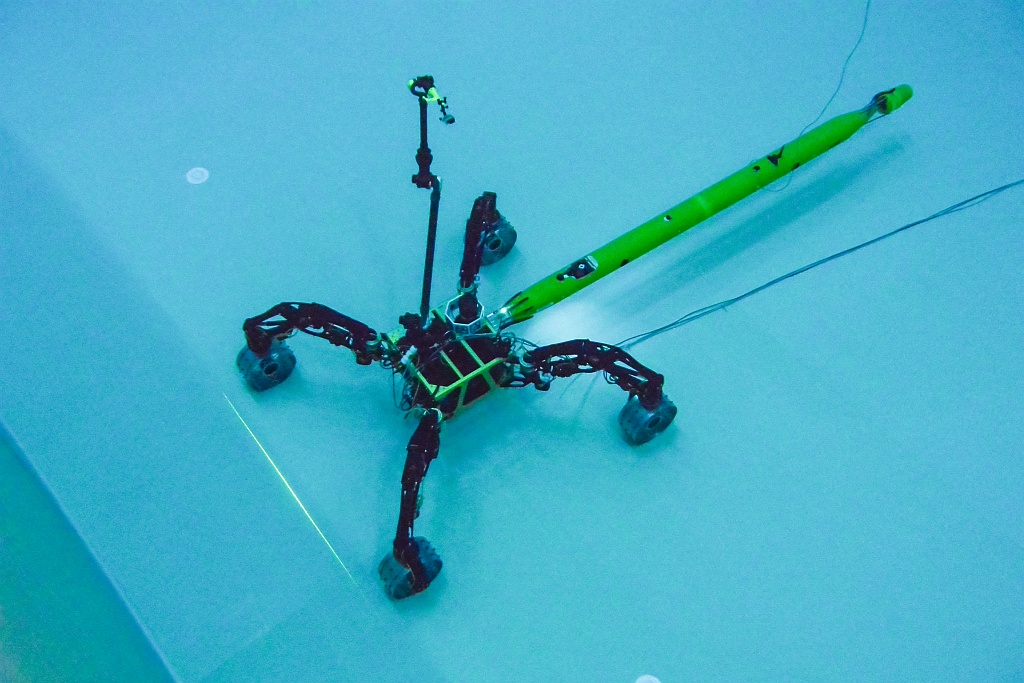 Bild: DFKI
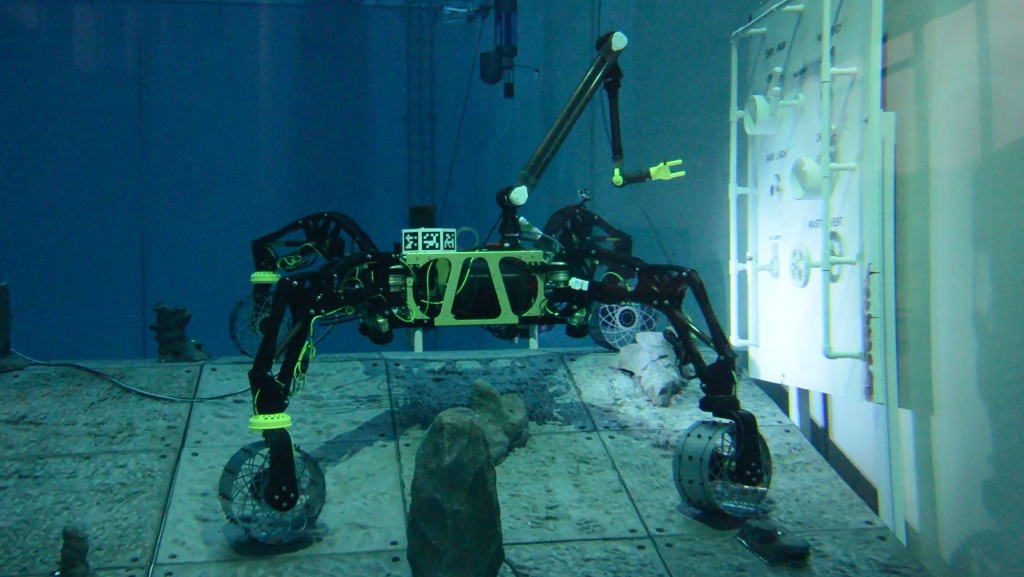 Bild: Thomas Frank, DFKI
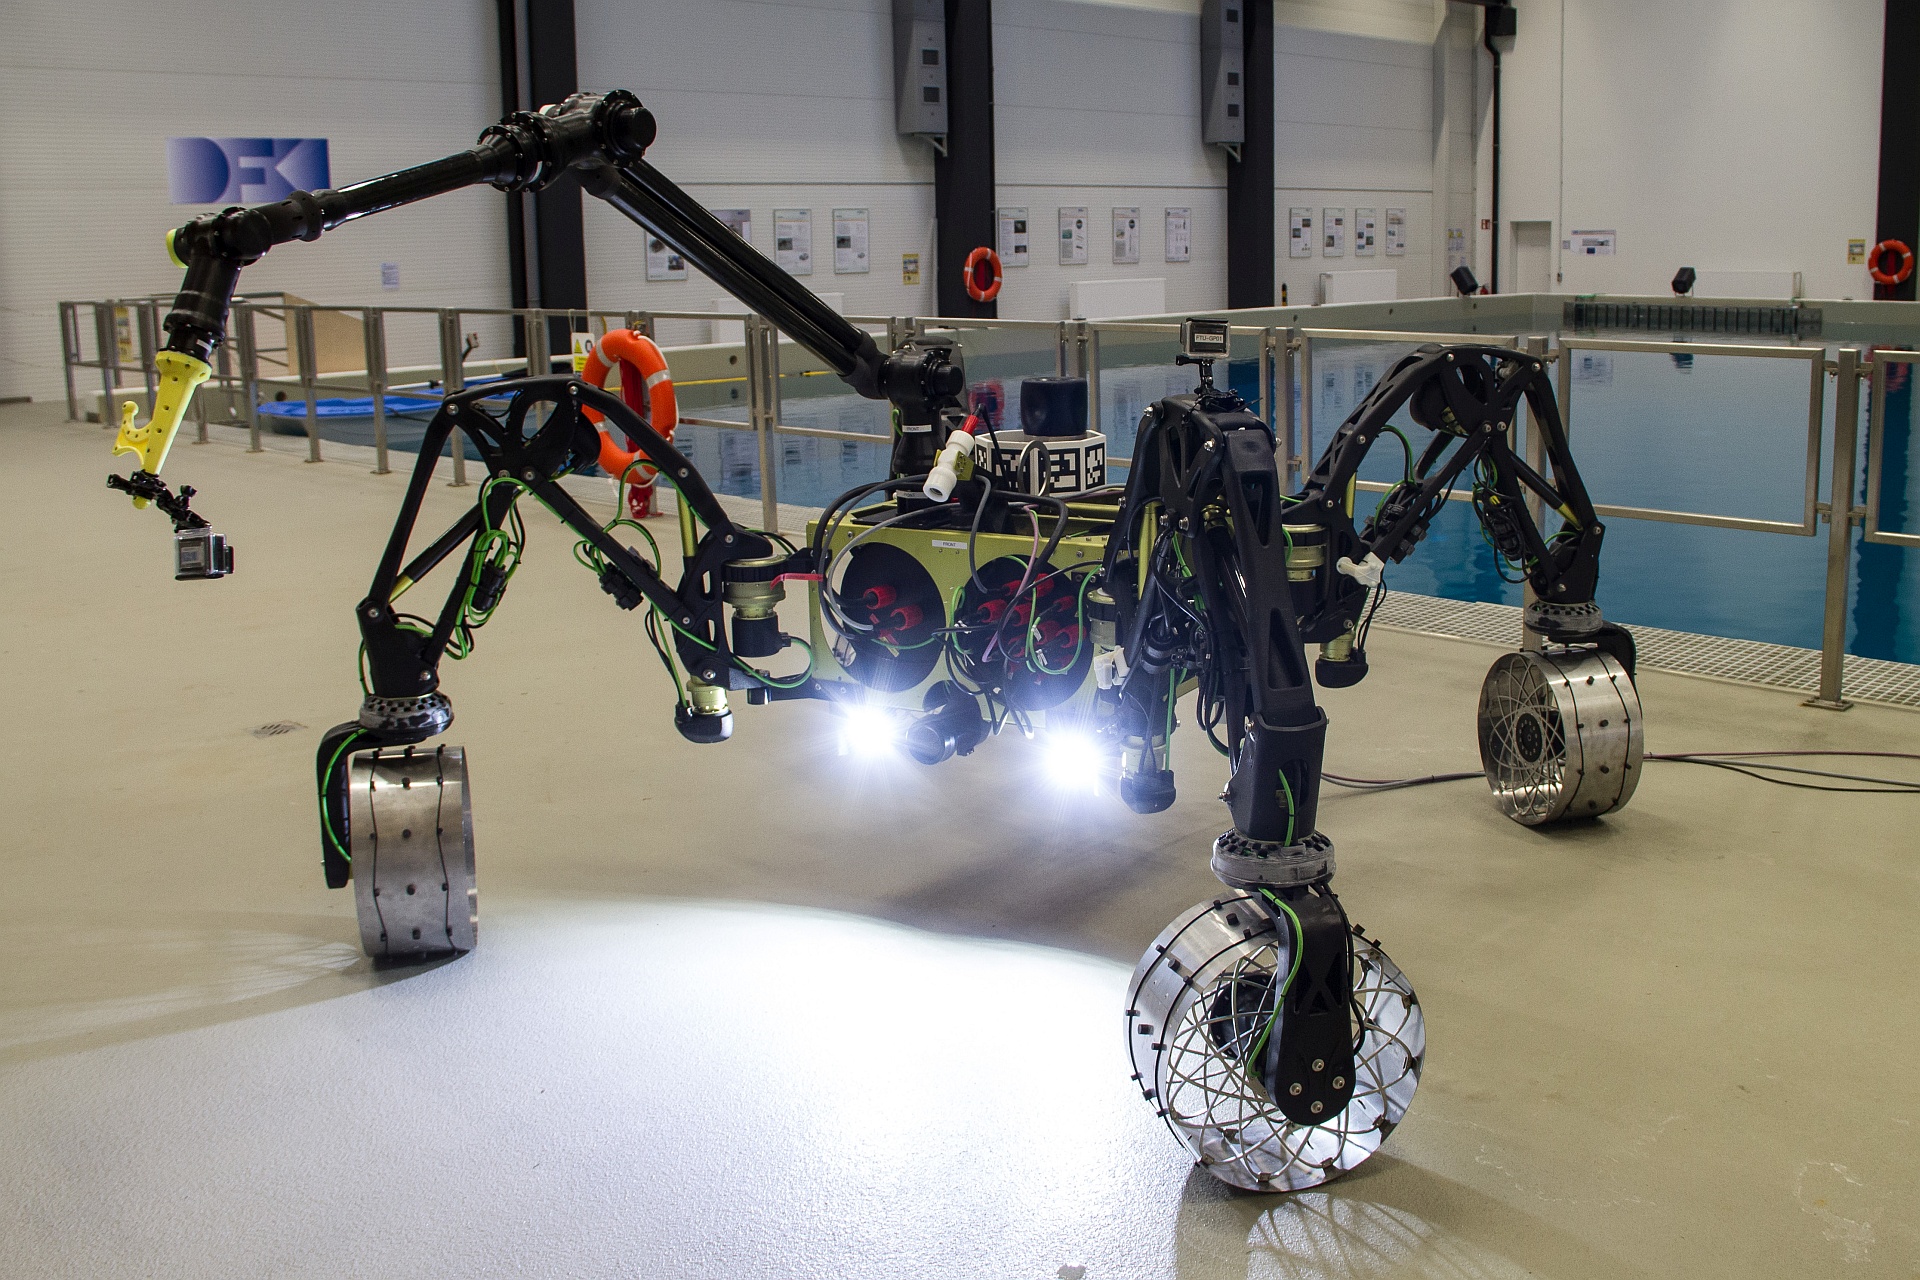 Bild: Thomas Frank, DFKI
SherpaUW is a hybrid walking and driving exploration rover for subsea applications. The locomotive system consists of four legs with 5 active DoF each. Additionally, a 6 DoF manipulation arm is available. All joints of the legs and the manipulation arm are sealed against water. The arm is pressure compensated, allowing the deployment in deep sea applications.
The actuators are rated for depths up to 100m without oil filling, while 6.000m are rated for pressure compensated actuators.
Possible areas of application include surveillance and maintenance for underwater infrastructures, exploration and resource utilization and research on maritime deep sea life. The rover can be deployed as a single system or as part of a maritime multi-robot system.
SherpaUW’s hybrid crawler-design is intended to allow for extended long-term missions on the sea floor. Since it requires no extra energy to maintain its posture and position compared to traditional underwater ROVs (Remotely Operated Vehicles), SherpaUW is well suited for repeated and precise sampling operations, for example monitoring black smockers over a longer period of time.
Videos
SherpaUW: Tests with hybrid underwater rover in the maritime exploration hall
