RH5
Humanoid robot as an assistance system in a human-optimized environment
 Foto: Heiner Peters, DFKI
Technical Details
System description
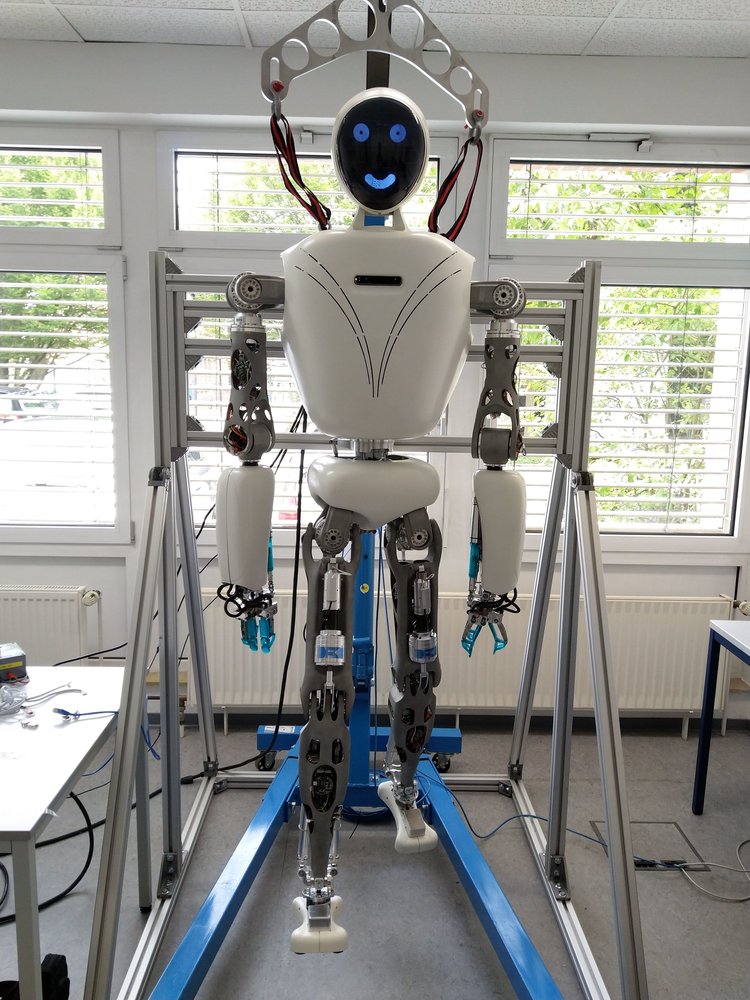 Foto: Heiner Peters, DFKI
The humanoid robot RH5 was developed as an assistance robot and against the background of long-term autonomous missions in environments designed for humans, e.g. on a future moon station. A humanoid design of the robot is suitable for interaction with humans as well as for locomotion and manipulation in a real environment. In addition to autonomous and semi-autonomous use, the robot should also be able to be teleoperated by means of an exoskeleton, whereby the visual perception and acting forces and torques of the robot are made available to the controlling person by means of virtual reality methods.
In the mechanical development, a hybrid serial parallel design architecture was employed to achieve a lightweight design with high stiffness and good dynamic properties. In addition to rotatory drive units, linear drive units are also used to exploit non-linear transmission properties.
Videos
RH5: Motion Capture State Feedback for Real-Time Control of a Humanoid Robot

The Video illustrates the results of the paper Mihaela Popescu, Dennis Mronga, Ivan Bergonzani, Shivesh Kumar, Frank Kirchner: "Experimental Investigations into Using Motion Capture State Feedback for Real-Time Control of a Humanoid Robot", Accepted for Publication: MDPI Sensors Journal, Special Issue "Advanced Sensors Technologies Applied in Mobile Robot", 2022.
RH5: Design, Analysis and Control of the Series-Parallel Hybrid RH5 Humanoid Robot

This paper presents a novel series-parallel hybrid humanoid called RH5 which is 2 m tall and weighs only 62.5 kg capable of performing heavy-duty dynamic tasks with 5 kg payloads in each hand. The analysis and control of this humanoid is performed with whole-body trajectory optimization technique based on differential dynamic programming (DDP). Additionally, we present an improved contact stability soft-constrained DDP algorithm which is able to generate physically consistent walking trajectories for the humanoid that can be tracked via a simple PD position control in a physics simulator. Finally, we showcase preliminary experimental results on the RH5 humanoid robot.