EurEx
Europa-Explorer

 Quelle: Marius Wirtz, DFKI GmbH
The project Europa-Explorer is a pilot survey for future missions to Jupiter's moon Europa. It focuses on the aspect of navigation of robotic systems on and especially under the ice-shield of Europa. Below the surface an ocean comprised of liquid water is expected. After penetration of the ice-shield an exploration can be conducted. A possible mission scenario is drafted, which covers all aspects of an exploration from the time of landing until the transmission of the survey results. In order to demonstrate the feasibility of this scenario, an experimental test platform will be constructed, which is able to be used in an analog mission at a suitable test site on earth. The results of this research can be used for planning purposes of real missions to Europa.
| Duration: | 01.12.2012 till 30.04.2016 |
| Performing institution: | German Research Center for Artificial Intelligence GmbH |
| Application Field: |
Underwater Robotics
Space Robotics |
| Related Projects: |
CUSLAM
Localization and mapping in confined underwater environments
(09.2009-
07.2012)
|
| Related Robots: |
BlueROV2
Documentation vehicle
DAGON
Exploration AUV for long-distance-missions
Teredo IceShuttle
Through-Ice-Cap Transfer-Vehicle & Base Station
Flatfish
Subsea-resident AUV
AUVx
A miniaturized autonomous underwater vehicle
DeepLeng
Exploration-AUV for Long-Term Missions
|
Funding

- Funding note
- The EurEx project is funded by the German Ministry for Economic Affairs and Climate Action (BMWI), Grant No. 50 NA 1217).
Project details
 Quelle: DFKI GmbH
 Foto: Bilal Wehbe, DFKI GmbH
 Foto: Annemarie Hirth, DFKI GmbH
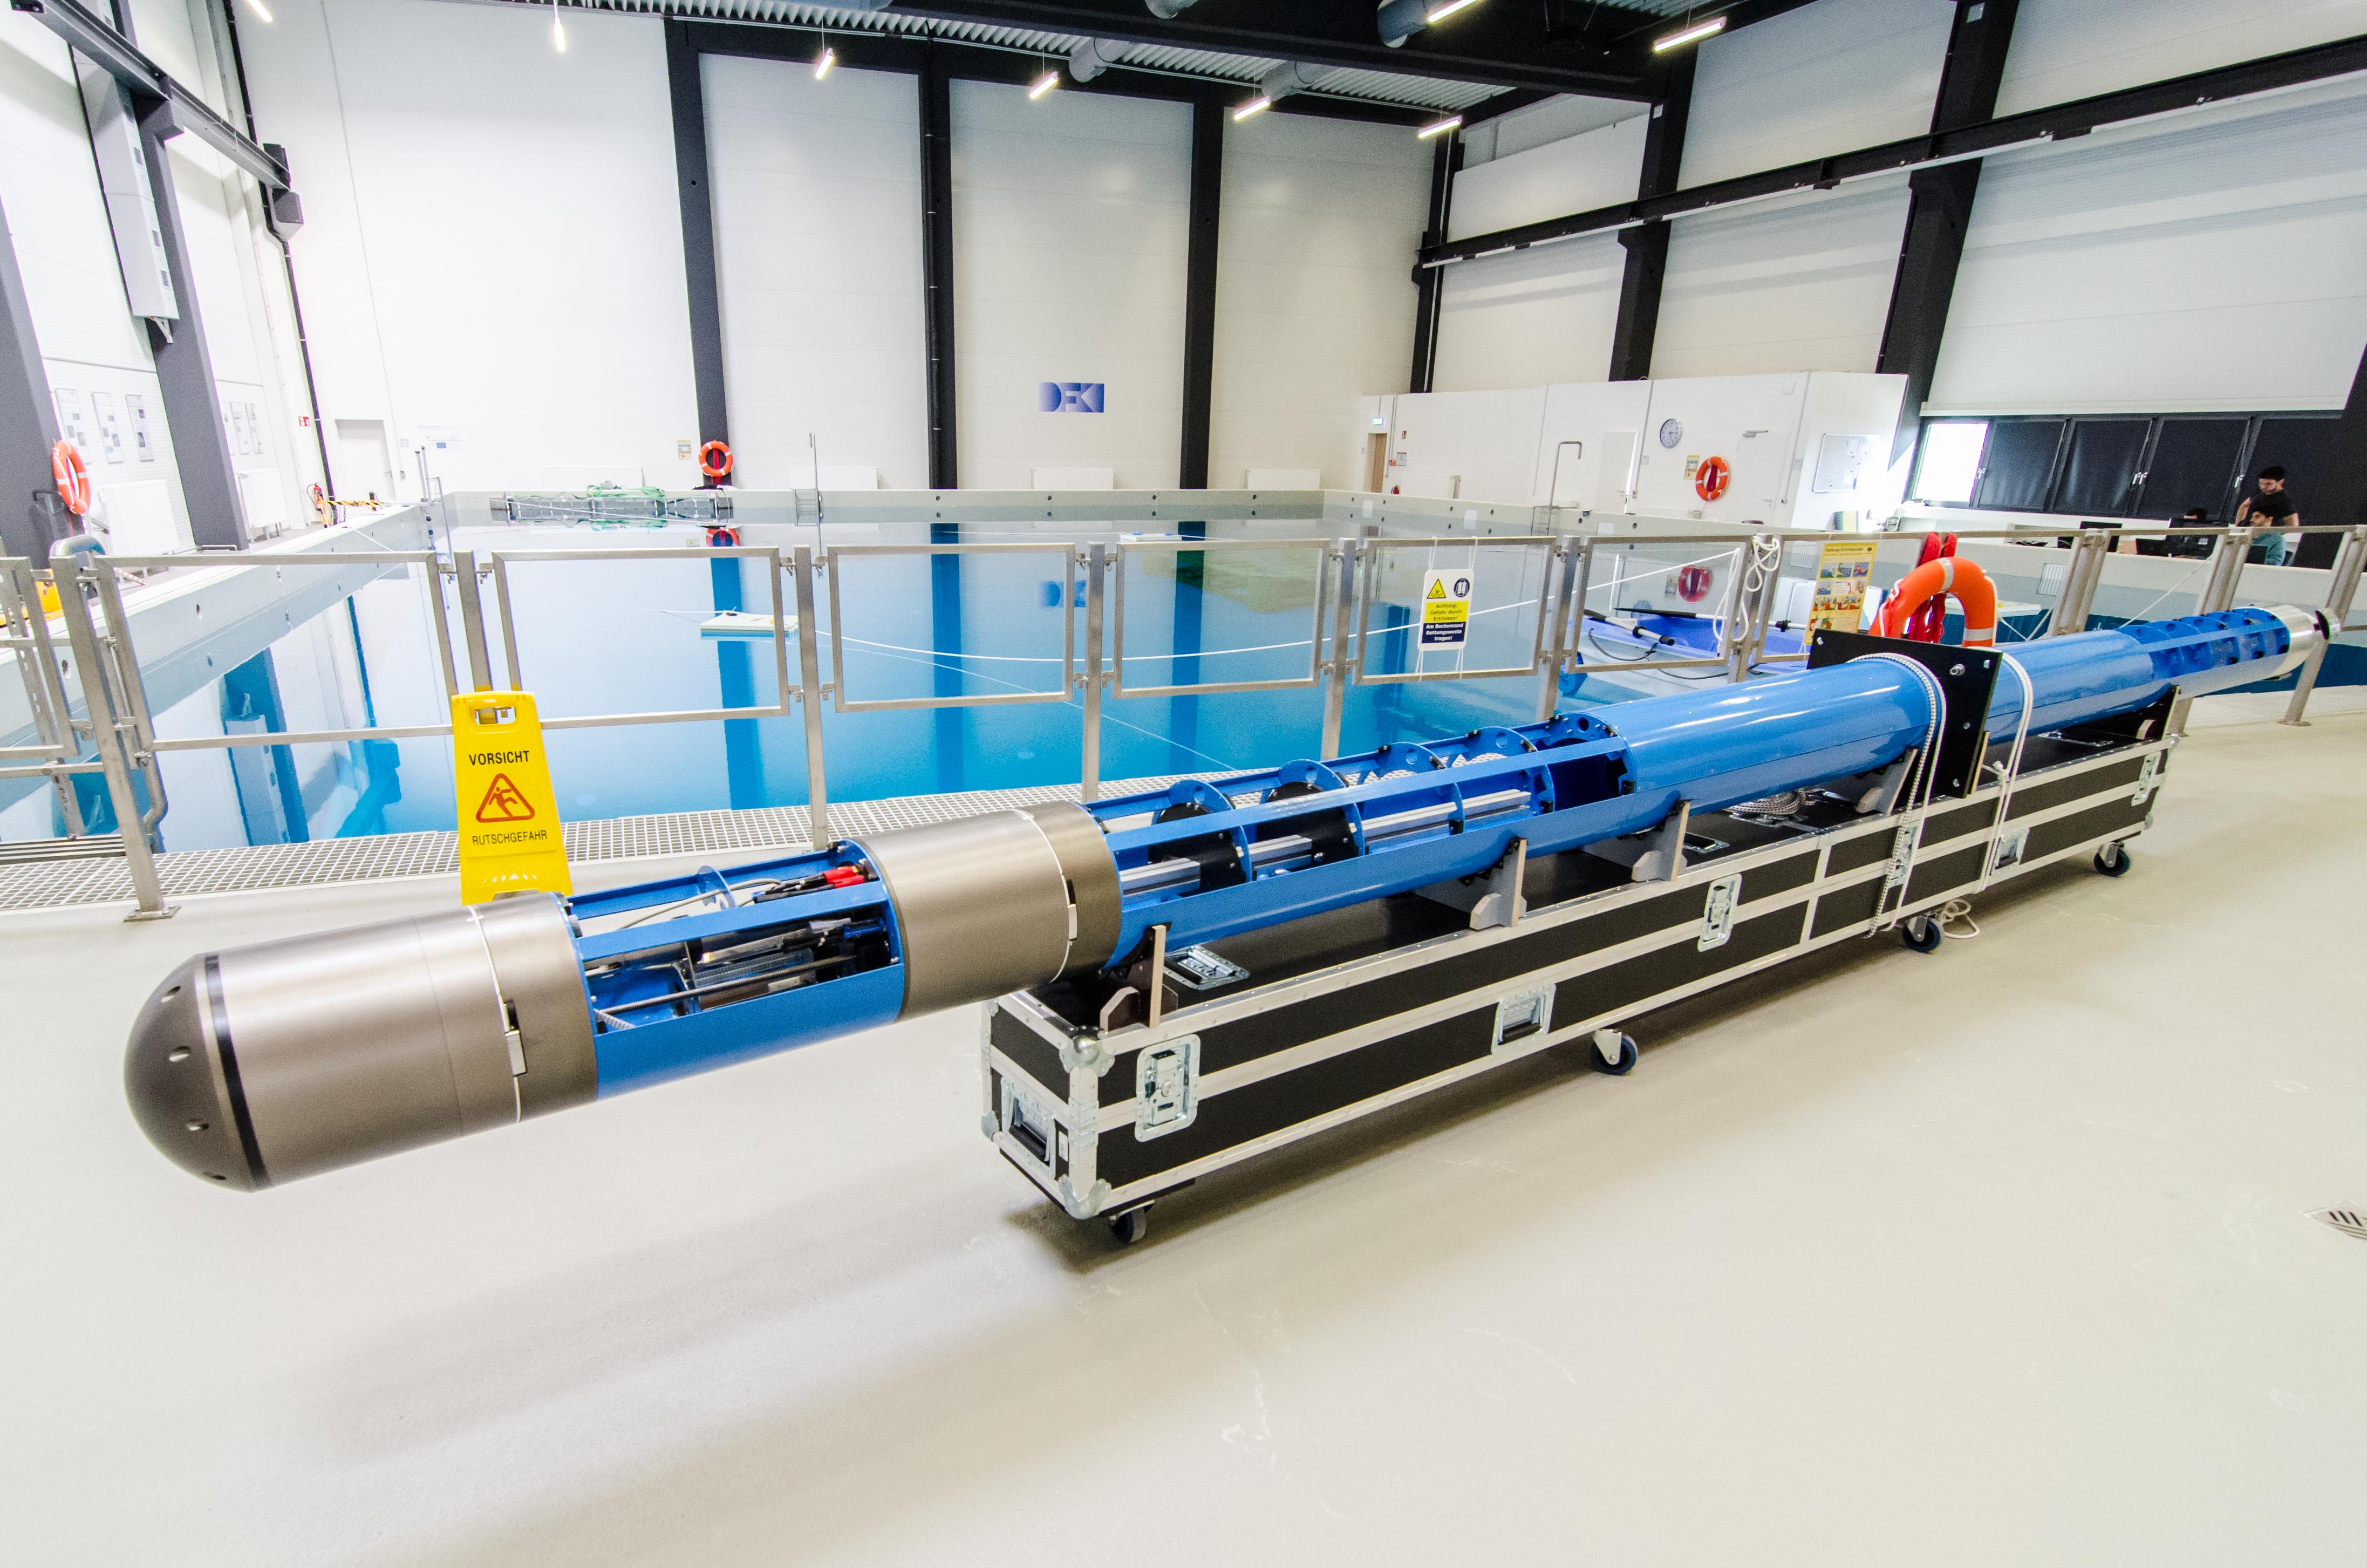 Foto: Jan Albiez, DFKI GmbH
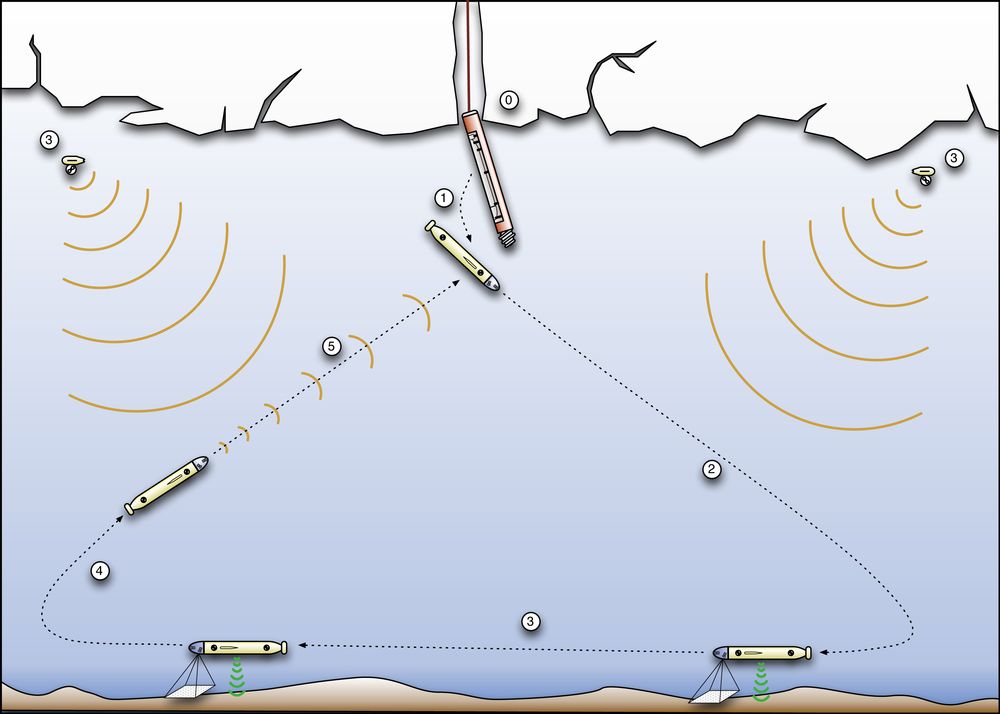
The project Europa-Explorer is a pilot survey for future missions to Jupiter's moon Europa. It focuses on the aspect of navigation of robotic systems on and especially under Europa's surface. Below Europa's ice shield (thickness between 3 and 15 kilometers) an ocean comprised of liquid water is expected. For the exploration of this ocean a fully-autonomous system is necessary due to the long run-time of communication from earth to Europa (33-53 minutes). After landing on Europa the system should execute the following tasks:
- Penetration of the ice shield
- Ejection of an exploration-AUV
- AUV sinks to ocean floor
- Autonomous exploration of the ocean floor and acquisition of measurement data
- Return to the point of entry
- Docking with the ice drill
- Return to the surface
The project Europa-Explorer will create a feasibility study for such a mission in a terrestrial scenario. Its main aspects are navigation under ice and integration of a functional complete exploration system out of the necessary components. A potential real mission is to be drafted together with the Max-Planck-Insitute for Solar System Research. In a two step process first the expected environmental conditions on Europa will be researched, which are the basis for validation experiments in terrestrial environments. In the second step the realizability of the drafted mission with respect to the usability of the build exploration system will be revised in detail. During the second step a possible concept for a full mission (including transit to Europa and landing) will be sketched
For the evaluation of the developments of this project an exploration-AUV and an ice-drill including a payload-section will be integrated as experiment platforms. The necessity for development of a new system lie in the high order of specialization of the two components: autonomous ice-drilling is a new area of research, especially with an integrated system including a payload system which is not available off the shelf. Regarding the AUV the problem is the specific necessity of a vehicle with small diameter (it needs to fit into the payload section of the ice-drill) with highly-specialized sensors for the exploration under ice - which in this combination are not available on the market, since typically under-ice-exploration AUVs are significantly bigger.
For experimental verification a compact system with all necessary sensors will be developed, which should be less than 20 cm in diameter. Diameters below this mark are preferable, but a compromise between necessary energy demand for ice-drilling and miniaturization of sensors is to be found during the project. AUV and ice-drill will have to be designed along-side in order to make the AUV fit the payload-section of the ice-drill. A special feature of the exploration AUV will be its hybrid propulsion system: besides the main propeller, it will comprise of a variable buoyancy cell (similar to an underwater glider system). This allows changes to overall buoyancy, enabling the AUV to traverse large vertical distances without continuous energy demands. This step is taken as preparation for a real mission to Europa, where an ocean of 100 km depth is expected to exist - much too deep for conventional, actively diving AUVs. The only possibility to provide enough energy to an AUV is to incorporate a RTG into its power system - due to risk of contamination this is deemed impossible for a real mission. Until completion of the exploration AUV the Dagon vehicle, built during the CUSLAM-project will be used as experimentation vehicle (see figure 1). A possible mission scenario including the interaction of ice-drill and AUV is depicted in figure 2.
The EurEx project is funded by the German Ministry of Economics (BMWI), Grant No. 50 NA 1217).
Videos
Europa-Explorer: Mission scenario

Animation of a possible mission on Jupiter’s moon Europa
Europa Explorer: LENG AUV undergoes an autonomous test mission

In this video, the Leng AUV undergoes an autonomous test mission in the saltwater basin of the DFKI Robotics Innovation Center. This mission is analogous to a potential mission in the ice-covered ocean of Jupiter's moon Europa. The vehicle undocks from the IceShuttle and then searches for gliders which act as acoustic navigation aids in a future mission. Following this, the AUV descends by modifying its buoyancy and gliding. Then, the vehicle searches the bottom for a black smoker. Finally, following an ascent (not shown), the vehicle docks again at the IceShuttle to transfer data. The robot-view images seen throughout the video is from data transferred at the end of the mission.
Publications(16)
16 publications · BibTeX · approx. 8 KB
2018
-
Conference
Miniaturized Underwater Gliders as Payload Transfer UnitsIn: Proceedings of the AUV 2018 MTS/OES Porto, Porto, PT · Nov 2018
-
Conference
Learning of Multi-Context Models for Autonomous Underwater VehiclesIn: Proceedings of the AUV 2018 IEEE/OES Porto, Porto, PT · Nov 2018
2017
-
Conference
Online Model Identification for Underwater Vehicles through Incremental Support Vector RegressionIn: IEEE/RSJ, Vancouver, CA, 4173-4180 · Sep 2017
-
Conference
Combining Cameras, Magnetometers and Machine-Learning into a Close-Range Localization System for Docking and HomingIn: MTS/IEEE Oceans 2017 Anchorage, Anchorage, US · Sep 2017
-
Conference
Learning Coupled Dynamic Models of Underwater Vehicles using Support Vector RegressionIn: Proceeding of Oceans '17 MTS/IEEE Aberdeen, Aberdeen, GB · Jun 2017
-
Conference
Experimental Evaluation of Various Machine Learning Regression Methods for Model Identification of Autonomous Underwater VehiclesIn: Proceedings of 2017 International Conference on Robotics and Automation (ICRA), Sands Expo and Convention Centre, SG, 4885-4890 · May 2017
2016
-
Journal
Cutting the Umbilical: New Technological Perspectives in Benthic Deep-Sea ResearchJournal of Marine Science and Engineering, 4(2), 1-27 · May 2016
-
Conference
IceShuttle Teredo: An Ice-Penetrating Robotic System to Transport an Exploration AUV into the Ocean of Jupiter's MoonEuropaIn: Proceedings of the 67th International Astronautical Congress, Guadalajara, MX · 2016
-
Conference
Europa Explorer - A mission concept to explore the ocean world of a Jovian ice moon.In: Master Conference 2016 - New Frontiers Ocean & Space - Marine Mining and Sustainability - Current Research and Future Challenges in Space, Bremen, DE · 2016
2015
- Report
2014
-
Journal
A Validation Process for Underwater Localization AlgorithmsInternational Journal of Advanced Robotic Systems, 11, 1-10 · Sep 2014
-
Report
Europa Explorer: Development of a Hydrodynamic Casing for the Autonomous Underwater VehicleIn: Proceedings of the RIC Project Day Workgroups Locomotion&Simulation, Bremen, DE · 2014
-
Conference
Navigation in Extreme Environments - Exploration of Jupiter's Moon Europa with Autonomous Underwater VehiclesIn: Luft- und Raumfahrt - Antrieb zu neuen Horizonten, Augsburg, DE · 2014
-
Conference
Towards an Astrobiological Vision for the Outer Solar System: The Europa and Enceladus Explorer Mission DesignsIn: Workshop on the Habitability of Icy Worlds, Pasadena, US · 2014
2013
-
PhD Thesis
Development, Evaluation and Validation of a Stereo Camera Underwater SLAM AlgorithmUniversität Bremen · Dec 2013
-
Conference
Design of an Autonomous Under-Ice Exploration SystemIn: MTS/IEEE Oceans 2013 San Diego, San Diego, US, 1-6 · Sep 2013